
 Share
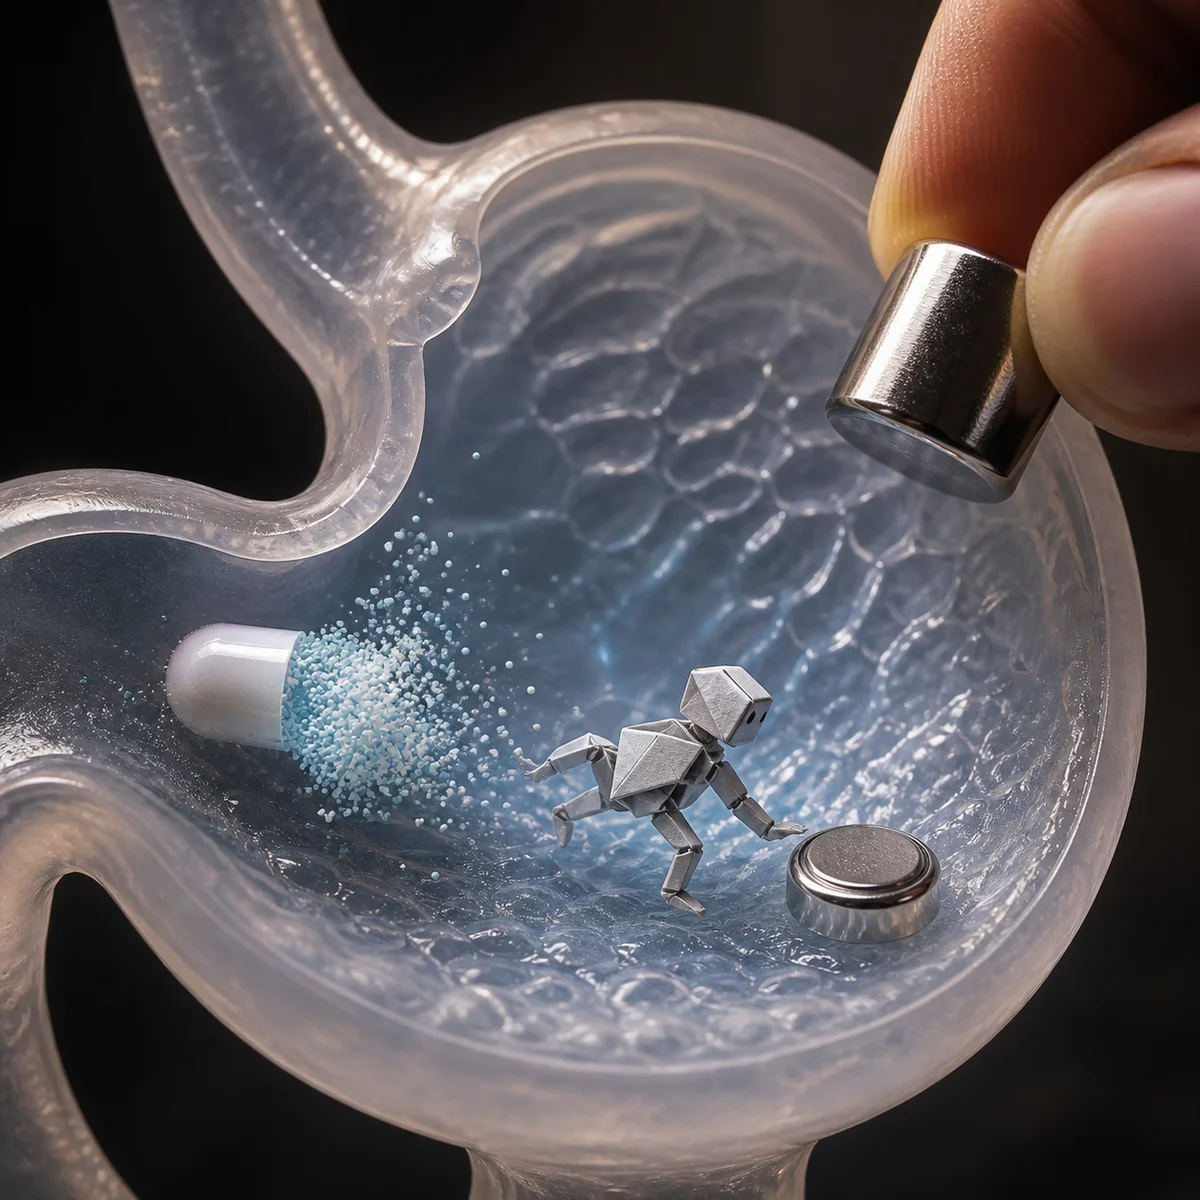
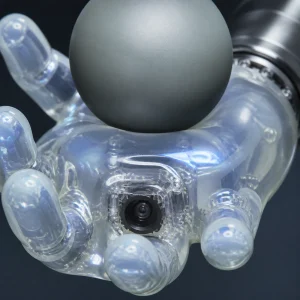
MIT engineers built a tiny robot around a shape change. Packed into an ingestible capsule, the device occupies little space. Once the casing dissolves, a folded structure opens, creating a larger working body that can move across a stomach-like surface. An external magnetic field steers it and supplies the interaction needed to crawl and manipulate an object.
In the reported demonstration, the robot retrieved a button battery from a simulated stomach. That target matters because swallowed batteries can injure tissue; a small device able to reach and remove one suggests a different path from passive capsules that only sense or release medicine. Origami geometry solves the delivery problem by letting a useful shape travel in a much smaller package.
The experiment remained a prototype, not a treatment used inside a person. Researchers worked with a silicone stomach model and animal-derived casing materials, so headlines about a robot operating in “the stomach” must keep the model visible. The mechanism is still compelling: fold a machine for entry, let the environment release it, guide it magnetically to a task, and then consider how future materials and testing might turn that controlled demonstration into safe medicine.
Sources